Automation project
Scalable 6-Axis Robotic Platform
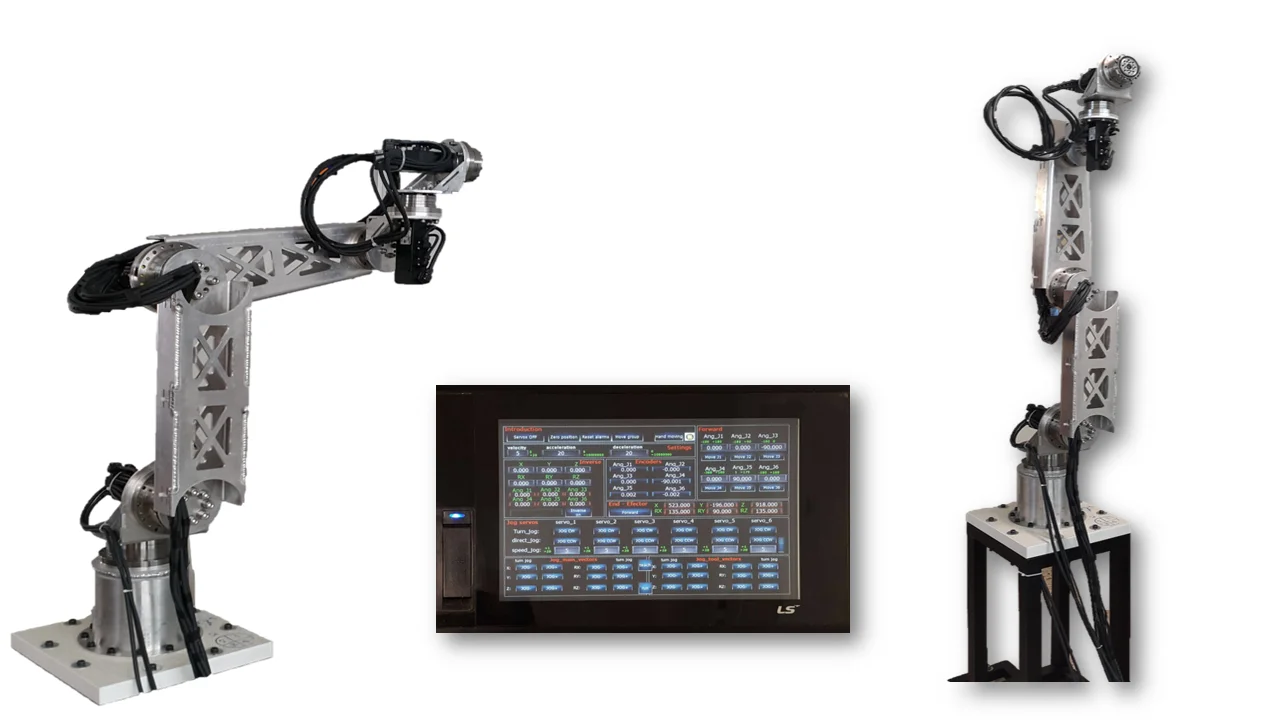
Modular 6-axis robot and motion controller for scalable production.
- Rockwell, Siemens, Omron, SolidWorks, Inventor
- P.Eng. support where required
- Usually reply within one business day
- On-site in Metro Vancouver & Fraser Valley
Challenge
A family of robots of different sizes needed one control approach, instead of separate controllers and software for each model.
Solution
A modular 6-axis robot and motion controller with a parameterized kinematic model, where arm and link lengths and axis geometry are configuration parameters. One cost-effective LS-based control architecture is shared across the family, with forward and inverse kinematics, joint-space and Cartesian motion, spherical and non-spherical wrists and coordinated multi-axis interpolation.
Platforms used
- LS-based control architecture
- Kinematic modeling
- Multi-axis motion control
Key points
- Parameterized kinematic model, arm/link lengths and axis geometry set as configuration parameters
- Cost-effective LS-based control architecture shared across the whole robot family
- Forward/inverse kinematics, joint-space & Cartesian motion, spherical/non-spherical wrists, coordinated multi-axis interpolation
Related services
Need something similar?
Fill out the form for a quote, or email your drawings. We usually reply within one business day.
PREFER EMAIL?
- Drawings, sketches or CAD (PDF, STEP, DWG)
- What you need: design, controls, or both
- Quantity, timeline and site location
- Rockwell, Siemens, Omron, SolidWorks, Inventor
- P.Eng. support where required
- Usually reply within one business day
- On-site in Metro Vancouver & Fraser Valley
Delta, BC, Canada